Autonomous reconnaissance before human entry.
MineX transforms underground mine rescue by performing autonomous reconnaissance first — mapping hazards, detecting survivors, and monitoring atmospheric conditions so that rescue teams can make informed, safer decisions.
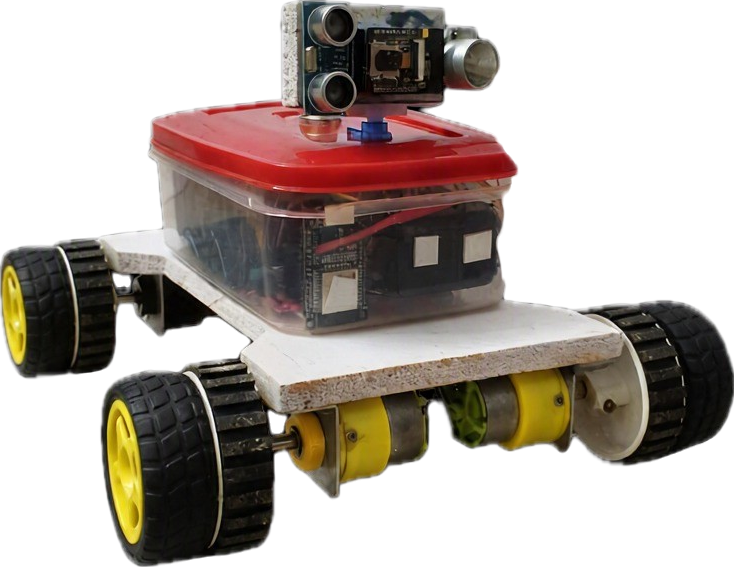
Decision Workflow
SENSE → UNDERSTAND → DECIDE → ACT
The Difference We Make
How MineX changes the approach to underground mine safety and rescue.
Safety Systems
Thermal Survivor Detection
FLIR Lepton 3.5 thermal camera detects human heat signatures through smoke, dust, and total darkness — alerting operators instantly.
Multi-Gas Hazard Monitoring
Industrial MEMS sensors continuously monitor CH₄, CO, H₂S, and O₃ levels, with automated hazard zone classification and alert escalation.
GPS-Free 3D Hazard Mapping
LiDAR + IMU SLAM creates real-time 3D tunnel maps with gas concentration overlays, enabling visual hazard zone identification.
Auto-Retrace Safe Return
When communication is lost, the rover autonomously retraces its SLAM path back to the last known relay node — ensuring it never gets lost.
Emergency Stop
A single command immediately halts all rover movement and motor activity for safety.
Continuous Atmospheric Monitoring
Real-time atmospheric data stream enables operators to make informed entry decisions before any human approaches the hazard zone.